ROS2 6-Axis Robot Arm Control
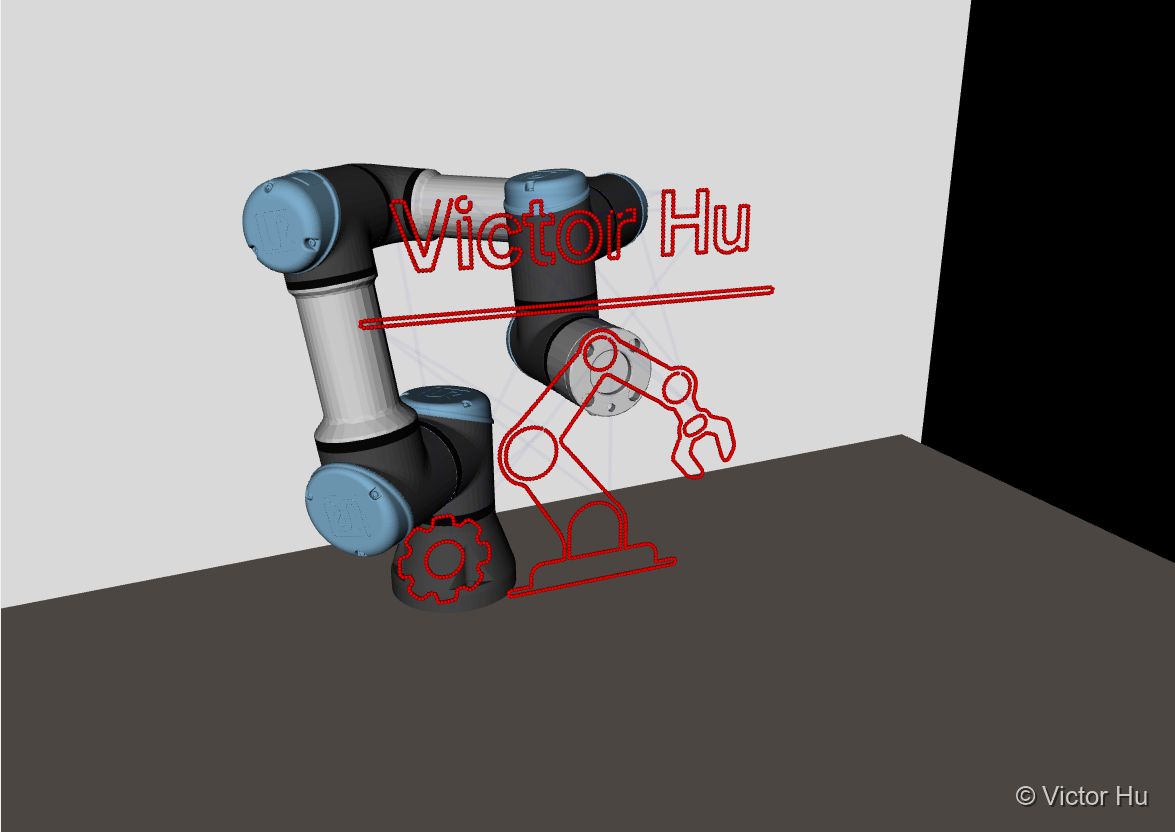
Simulated and controlled a 6-axis arm in ROS2, executing planned drawing trajectories.
A hands-on ROS2 project built around a 6-axis manipulator. I modeled and controlled the arm in simulation, using RViz to visualize joint states and the planned end-effector path before anything moved.
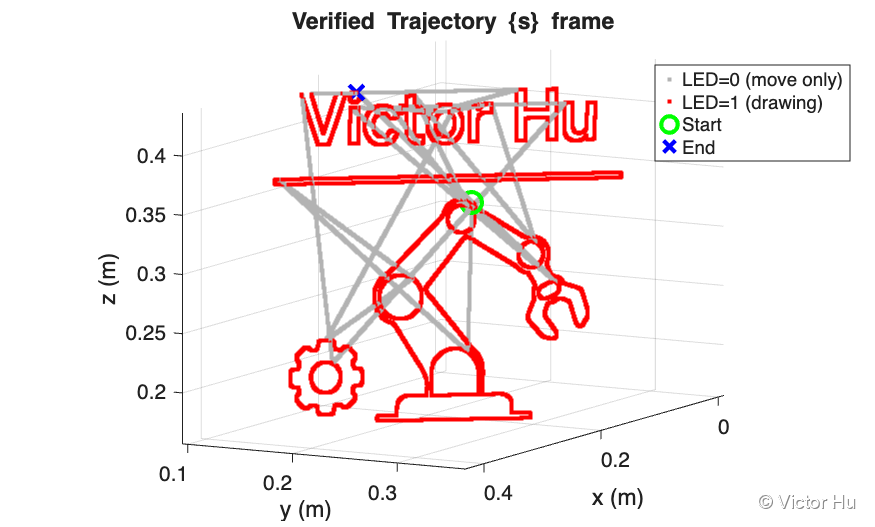
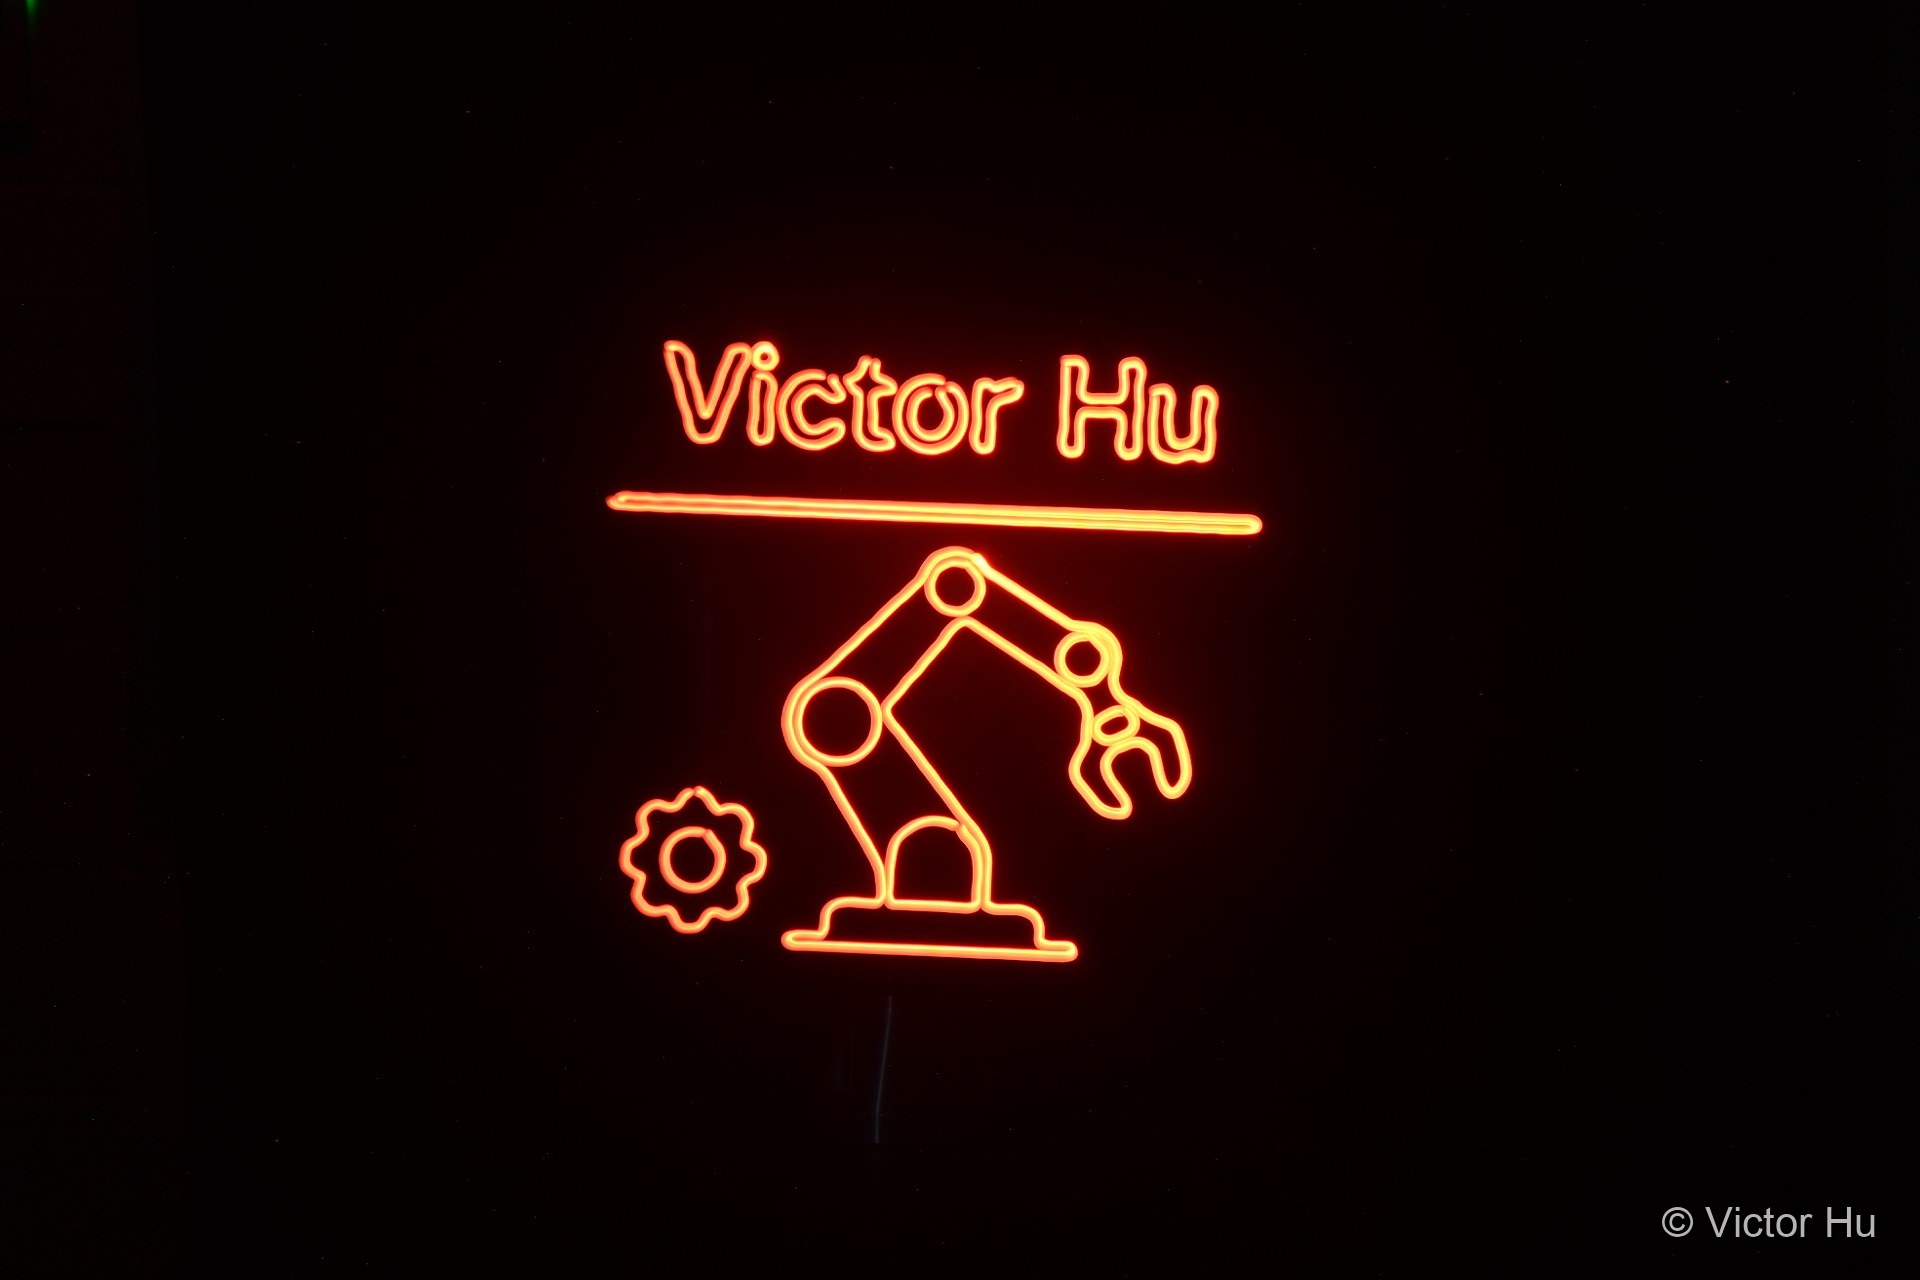
The core of the work was the motion stack: Python nodes that take a target path, solve for the joint trajectories, and stream them to the controller. To prove the pipeline end-to-end, I drove the arm through drawing tasks, following Cartesian paths accurately enough to trace shapes, which exercises kinematics, planning, and timing together rather than in isolation.
Project highlights
- Simulated and controlled a 6-axis robotic arm in ROS2 with RViz visualization
- Wrote Python nodes for path planning and trajectory generation
- Executed complex drawing tasks end-to-end from plan to motion
Project media